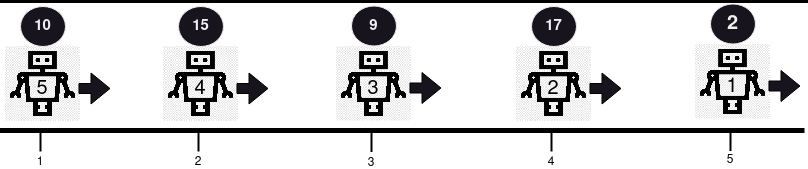
There are n 1-indexed robots, each having a position on a line, health, and movement direction.You are given 0-indexed integer arrays positions, healths, and a string directions (directions[i] is either ‘L’ for left or ‘R’ for right). All integers in positions are unique.All robots start moving on the line simultaneously at the same speed in their given directions. If two robots ever share the same position while moving, they will collide.If two robots collide, the robot with lower health is removed from the line, and the health of the other robot decreases by one. The surviving robot continues in the same direction it was going. If both robots have the same health, they are both removed from the line.Your task is to determine the health of the robots that survive the collisions, in the same order that the robots were given, i.e. final health of robot 1 (if survived), final health of robot 2 (if survived), and so on. If there are no survivors, return an empty array.Return an array containing the health of the remaining robots (in the order they were given in the input), after no further collisions can occur.Note: The positions may be unsorted.
Input: positions = [5,4,3,2,1], healths = [2,17,9,15,10], directions = "RRRRR"Output: [2,17,9,15,10]Explanation: No collision occurs in this example, since all robots are moving in the same direction. So, the health of the robots in order from the first robot is returned, [2, 17, 9, 15, 10].
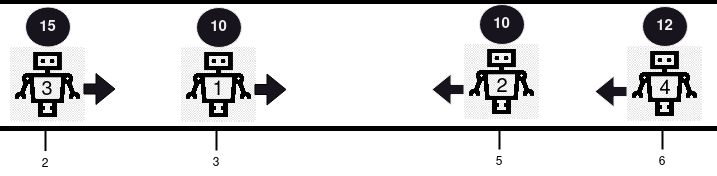
Input: positions = [3,5,2,6], healths = [10,10,15,12], directions = "RLRL"Output: [14]Explanation: There are 2 collisions in this example. Firstly, robot 1 and robot 2 will collide, and since both have the same health, they will be removed from the line. Next, robot 3 and robot 4 will collide and since robot 4's health is smaller, it gets removed, and robot 3's health becomes 15 - 1 = 14. Only robot 3 remains, so we return [14].
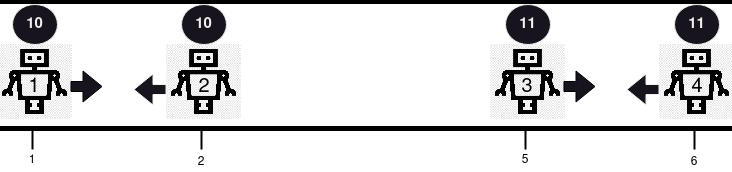
Input: positions = [1,2,5,6], healths = [10,10,11,11], directions = "RLRL"Output: []Explanation: Robot 1 and robot 2 will collide and since both have the same health, they are both removed. Robot 3 and 4 will collide and since both have the same health, they are both removed. So, we return an empty array, [].
{"docsConfig":{"theme":"mint","$schema":"https://www.mintlify.com/docs.json","name":"leetcode-py","description":"Modern Python LeetCode practice environment with automated problem generation, beautiful data structure visualizations, and comprehensive testing","colors":{"primary":"#3776AB","light":"#5A94C4","dark":"#387EB8"},"logo":{"light":"https://mintcdn.com/leetcode-py/aJKJ4BOUnXP-zM3G/img/brand/leetcode-py-lockup.svg?fit=max\u0026auto=format\u0026n=aJKJ4BOUnXP-zM3G\u0026q=85\u0026s=34c74a404ed256642a54345a92489c97","dark":"https://mintcdn.com/leetcode-py/aJKJ4BOUnXP-zM3G/img/brand/leetcode-py-lockup-dark.svg?fit=max\u0026auto=format\u0026n=aJKJ4BOUnXP-zM3G\u0026q=85\u0026s=263c5757fbf5e547de96291651e279e9"},"favicon":"https://mintcdn.com/leetcode-py/VCrzlUI648LnF7Pk/favicon.svg?fit=max\u0026auto=format\u0026n=VCrzlUI648LnF7Pk\u0026q=85\u0026s=3b1dffe162e80798a504a810fcbeba45","background":{"color":{"light":"#F8F9FB","dark":"#0D1117"}},"navbar":{"links":[{"href":"https://github.com/wislertt/leetcode-py","label":"GitHub"}]},"footer":{"socials":{"github":"https://github.com/wislertt/leetcode-py"},"links":[{"header":"Resources","items":[{"label":"PyPI","href":"https://pypi.org/project/leetcode-py-sdk"},{"label":"Why leetcode-py","href":"/getting-started/why-leetcode-py"},{"label":"Made by Wisaroot Lertthaweedech","href":"https://wisl.dev"}]}]},"seo":{"metatags":{"canonical":"https://leetcode-py.wisl.dev","og:image":"https://leetcode-py.wisl.dev/img/brand/og-card-light.png","twitter:card":"summary_large_image"},"organization":{"url":"https://leetcode-py.wisl.dev","sameAs":["https://github.com/wislertt/leetcode-py","https://pypi.org/project/leetcode-py-sdk/","https://wisl.dev"]},"indexing":"all"},"styling":{"codeblocks":{"theme":{"light":"github-light","dark":"github-dark"}},"latex":true},"metadata":{"timestamp":true},"markdown":{"instructions":["leetcode-py is a Python LeetCode practice environment generator with one CLI: lcpy. It is not a service or platform.","Each problem is a directory under leetcode/ with README.md, solution.py, test_solution.py, helpers.py, and playground.ipynb. lcpy gen creates them from JSON templates bundled with the package.","Examples are backed by tests; copy them verbatim."]},"navigation":{"pages":[]}},"deployment":{"deploymentMetadataValue":{"subdomain":"leetcode-py","hasAudioNarration":false,"actualSubdomain":"leetcode-py","customDomains":["leetcode-py.wisl.dev"],"gitSource":{"type":"github","owner":"wislertt","repo":"leetcode-py","deployBranch":"main","contentDirectory":"docs","isPrivate":true,"mountPath":"","label":""},"entitlements":{},"buildId":"6aeadd835fa1f5f231996c95","clientVersion":"0.0.4094","searchFilterCounts":[{"language":"default","tag":"Catalog","count":13},{"language":"default","tag":"Practice","count":5},{"language":"default","tag":"Troubleshooting","count":5},{"language":"default","tag":"Getting Started","count":3},{"language":"default","tag":"CLI","count":2},{"language":"default","tag":"Contributing","count":2},{"language":"default","tag":"Welcome","count":1}]},"assistantConfig":{"enableAskAiButton":false,"enableStarterQuestions":false,"enableContextualStarterQuestions":false,"enableAskAiSearchBar":true},"basePath":"","hasChatPermissions":false,"hasWebMcpPermissions":false,"toggles":[{"name":"kill-isr","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"agent-mintlify-slack","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"agent-integrations-settings","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"rbac-expansion","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automations-pr-grouping","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"custom-prefix","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"analytics-v7","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"user-flows-analytics","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"no-publish-flow","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workos-onboarding","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"llms-txt-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"snapshot-serving-live","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"stripTemperatureMiddleware","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"support-platform-pylon-zendesk","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"snapshot-serving","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"instant-rollback","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"granular-notifications-server","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"granular-notifications","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automations-fable","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"fixed-ai-action-pricing","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automation-resolve-merge-conflict","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"scoped-publishing","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"mintql","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"page-level-analytics","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-version-history-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"billing-page-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"full-page-search","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workspace-projects","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"assistant-v5","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"fork-pr-previews","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"revalidation-jwt","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workos-sso-scim","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"hobby-abuse-scan","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"dashboard-inbox","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workos-signup","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"turbopuffer-dual-write","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workos-enabled","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"approve-review-flow","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-metadata","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"sso-setup-deadline-banner","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"turbopuffer-serve","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"live-agents","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"comment-mode","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false}],"googleFontsInlined":false},"customCss":[{"filePath":"custom.css","content":".sd-catalog-table th:first-child,.sd-catalog-table td:first-child{min-width:0;width:3rem}html.dark .sd-hero-light{display:none}html:not(.dark) .sd-hero-dark{display:none}.sd-badges{display:flex;flex-wrap:wrap;gap:8px;align-items:center;justify-content:flex-start;margin:0 0 16px;padding:0}.sd-badges a,.sd-badges a:hover,.sd-badges a:visited{display:inline-flex;flex:0 0 auto;line-height:0;height:auto!important;max-height:24px;padding:0!important;margin:0!important;text-decoration:none!important;border-bottom:none!important;background:none!important;background-image:none!important}.sd-badges img{height:20px;width:auto;max-width:none;display:block;margin:0!important}.sd-preview{border:1px solid #387eb8;border-radius:10px}"}],"page":{"pagePath":"problems/robot-collisions","slug":"/problems/robot-collisions","pageMetadata":{"title":"Robot Collisions Python Solution with Tests","description":"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.","href":"/problems/robot-collisions"},"description":{"compiledSource":"\"use strict\";\nconst {jsx: _jsx} = arguments[0];\nconst {useMDXComponents: _provideComponents} = arguments[0];\nfunction _createMdxContent(props) {\n const _components = {\n p: \"p\",\n ..._provideComponents(),\n ...props.components\n };\n return _jsx(_components.p, {\n children: \"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\"\n });\n}\nfunction MDXContent(props = {}) {\n const {wrapper: MDXLayout} = {\n ..._provideComponents(),\n ...props.components\n };\n return MDXLayout ? _jsx(MDXLayout, {\n ...props,\n children: _jsx(_createMdxContent, {\n ...props\n })\n }) : _createMdxContent(props);\n}\nreturn {\n default: MDXContent\n};\n","frontmatter":{},"scope":{}},"pageType":"default","mdx":{"mdxSource":{"compiledSource":"\"use strict\";const{Fragment:_Fragment,jsx:_jsx,jsxs:_jsxs}=arguments[0];const{useMDXComponents:_provideComponents}=arguments[0];function _createMdxContent(props){const _components={a:`a`,code:`code`,img:`img`,li:`li`,p:`p`,pre:`pre`,span:`span`,tbody:`tbody`,td:`td`,th:`th`,thead:`thead`,tr:`tr`,ul:`ul`,..._provideComponents(),...props.components},{CodeBlock,Heading,Table}=_components;if(!CodeBlock)_missingMdxReference(`CodeBlock`,true);if(!Heading)_missingMdxReference(`Heading`,true);if(!Table)_missingMdxReference(`Table`,true);return _jsxs(_Fragment,{children:[_jsxs(_components.p,{children:[`LeetCode 2751, `,_jsx(_components.a,{href:`/catalog/hard`,children:`Hard`}),`. Topics: `,_jsx(_components.a,{href:`/catalog/topics/array`,children:`Array`}),`, `,_jsx(_components.a,{href:`/catalog/topics/stack`,children:`Stack`}),`, `,_jsx(_components.a,{href:`/catalog/topics/sorting`,children:`Sorting`}),`, `,_jsx(_components.a,{href:`/catalog/topics/simulation`,children:`Simulation`}),`. `,_jsx(_components.a,{href:`https://leetcode.com/problems/robot-collisions/description/`,children:`View on LeetCode`}),`.`]}),`\n`,_jsxs(_components.p,{children:[`Generate this problem as a practice environment: tested reference solution, 30 `,_jsx(_components.a,{href:`/practice/testing`,children:`parametrized pytest cases`}),`, and a playground notebook:`]}),`\n`,_jsx(CodeBlock,{filename:``,numberOfLines:`2`,language:`shellscript`,children:_jsx(_components.pre,{className:`shiki shiki-themes github-light github-dark`,style:{backgroundColor:`#fff`,\"--shiki-dark-bg\":`#24292e`,color:`#24292e`,\"--shiki-dark\":`#e1e4e8`},language:`shellscript`,children:_jsxs(_components.code,{language:`shellscript`,numberOfLines:`2`,children:[_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:`lcpy gen -n 2751 `}),_jsx(_components.span,{style:{color:`#6A737D`,\"--shiki-dark\":`#6A737D`},children:`# by problem number`})]}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:`lcpy gen -s robot_collisions `}),_jsx(_components.span,{style:{color:`#6A737D`,\"--shiki-dark\":`#6A737D`},children:`# by problem name`})]}),`\n`]})})}),`\n`,_jsx(Heading,{level:`2`,id:`problem`,children:`Problem`}),`\n`,_jsx(_components.p,{children:`There are n 1-indexed robots, each having a position on a line, health, and movement direction.`}),`\n`,_jsx(_components.p,{children:`You are given 0-indexed integer arrays positions, healths, and a string directions (directions[i] is either ‘L’ for left or ‘R’ for right). All integers in positions are unique.`}),`\n`,_jsx(_components.p,{children:`All robots start moving on the line simultaneously at the same speed in their given directions. If two robots ever share the same position while moving, they will collide.`}),`\n`,_jsx(_components.p,{children:`If two robots collide, the robot with lower health is removed from the line, and the health of the other robot decreases by one. The surviving robot continues in the same direction it was going. If both robots have the same health, they are both removed from the line.`}),`\n`,_jsx(_components.p,{children:`Your task is to determine the health of the robots that survive the collisions, in the same order that the robots were given, i.e. final health of robot 1 (if survived), final health of robot 2 (if survived), and so on. If there are no survivors, return an empty array.`}),`\n`,_jsx(_components.p,{children:`Return an array containing the health of the remaining robots (in the order they were given in the input), after no further collisions can occur.`}),`\n`,_jsx(_components.p,{children:`Note: The positions may be unsorted.`}),`\n`,_jsx(Heading,{level:`3`,id:`examples`,children:`Examples`}),`\n`,_jsx(_components.p,{children:_jsx(_components.img,{src:`https://assets.leetcode.com/uploads/2023/05/15/image-20230516011718-12.png`,alt:`Example 1`})}),`\n`,_jsx(CodeBlock,{numberOfLines:`4`,language:`text`,children:_jsx(_components.pre,{className:`shiki shiki-themes github-light github-dark`,style:{backgroundColor:`#fff`,\"--shiki-dark-bg\":`#24292e`,color:`#24292e`,\"--shiki-dark\":`#e1e4e8`},language:`text`,children:_jsxs(_components.code,{language:`text`,numberOfLines:`4`,children:[_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Input: positions = [5,4,3,2,1], healths = [2,17,9,15,10], directions = \"RRRRR\"`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Output: [2,17,9,15,10]`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Explanation: No collision occurs in this example, since all robots are moving in the same direction. So, the health of the robots in order from the first robot is returned, [2, 17, 9, 15, 10].`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{})})]})})}),`\n`,_jsx(_components.p,{children:_jsx(_components.img,{src:`https://assets.leetcode.com/uploads/2023/05/15/image-20230516004433-7.png`,alt:`Example 2`})}),`\n`,_jsx(CodeBlock,{numberOfLines:`4`,language:`text`,children:_jsx(_components.pre,{className:`shiki shiki-themes github-light github-dark`,style:{backgroundColor:`#fff`,\"--shiki-dark-bg\":`#24292e`,color:`#24292e`,\"--shiki-dark\":`#e1e4e8`},language:`text`,children:_jsxs(_components.code,{language:`text`,numberOfLines:`4`,children:[_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Input: positions = [3,5,2,6], healths = [10,10,15,12], directions = \"RLRL\"`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Output: [14]`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Explanation: There are 2 collisions in this example. Firstly, robot 1 and robot 2 will collide, and since both have the same health, they will be removed from the line. Next, robot 3 and robot 4 will collide and since robot 4's health is smaller, it gets removed, and robot 3's health becomes 15 - 1 = 14. Only robot 3 remains, so we return [14].`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{})})]})})}),`\n`,_jsx(_components.p,{children:_jsx(_components.img,{src:`https://assets.leetcode.com/uploads/2023/05/15/image-20230516005114-9.png`,alt:`Example 3`})}),`\n`,_jsx(CodeBlock,{numberOfLines:`4`,language:`text`,children:_jsx(_components.pre,{className:`shiki shiki-themes github-light github-dark`,style:{backgroundColor:`#fff`,\"--shiki-dark-bg\":`#24292e`,color:`#24292e`,\"--shiki-dark\":`#e1e4e8`},language:`text`,children:_jsxs(_components.code,{language:`text`,numberOfLines:`4`,children:[_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Input: positions = [1,2,5,6], healths = [10,10,11,11], directions = \"RLRL\"`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Output: []`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{children:`Explanation: Robot 1 and robot 2 will collide and since both have the same health, they are both removed. Robot 3 and 4 will collide and since both have the same health, they are both removed. So, we return an empty array, [].`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{})})]})})}),`\n`,_jsx(Heading,{level:`3`,id:`constraints`,children:`Constraints`}),`\n`,_jsxs(_components.ul,{children:[`\n`,_jsx(_components.li,{children:`1 \u003c= positions.length == healths.length == directions.length == n \u003c= 10^5`}),`\n`,_jsx(_components.li,{children:`1 \u003c= positions[i], healths[i] \u003c= 10^9`}),`\n`,_jsxs(_components.li,{children:[_jsx(_components.code,{children:`directions[i]`}),` is `,_jsx(_components.code,{children:`'L'`}),` or `,_jsx(_components.code,{children:`'R'`})]}),`\n`,_jsxs(_components.li,{children:[`All values in `,_jsx(_components.code,{children:`positions`}),` are distinct`]}),`\n`]}),`\n`,_jsx(Heading,{level:`2`,id:`solution`,children:`Solution`}),`\n`,_jsxs(_components.p,{children:[`Reference implementation from `,_jsx(_components.a,{href:`https://github.com/wislertt/leetcode-py/blob/main/leetcode/robot_collisions/solution.py`,children:`solution.py on GitHub`}),`, full suite in `,_jsx(_components.a,{href:`https://github.com/wislertt/leetcode-py/blob/main/leetcode/robot_collisions/test_solution.py`,children:`test_solution.py`}),`:`]}),`\n`,_jsx(CodeBlock,{filename:``,numberOfLines:`26`,language:`python`,children:_jsx(_components.pre,{className:`shiki shiki-themes github-light github-dark`,style:{backgroundColor:`#fff`,\"--shiki-dark-bg\":`#24292e`,color:`#24292e`,\"--shiki-dark\":`#e1e4e8`},language:`python`,children:_jsxs(_components.code,{language:`python`,numberOfLines:`26`,children:[_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`class`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` Solution:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#6A737D`,\"--shiki-dark\":`#6A737D`},children:` # Time: O(n log n)`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#6A737D`,\"--shiki-dark\":`#6A737D`},children:` # Space: O(n)`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` def`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` survived_robots_healths(`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` self, positions: list[int], healths: list[int], directions: str`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` ) -> list[int]:`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining = list(healths)`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` stack: list[int] = []`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` for`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` i `}),_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`in`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` sorted(range(len(positions)), key=positions.__getitem__):`})]}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` if`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` directions[i] == `}),_jsx(_components.span,{style:{color:`#032F62`,\"--shiki-dark\":`#9ECBFF`},children:`\"R\"`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:`:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` stack.append(i)`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` continue`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` while`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` stack `}),_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`and`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[i] > 0:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` j = stack[-1]`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` if`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[j] > remaining[i]:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[j] -= 1`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[i] = 0`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` elif`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[j] \u003c remaining[i]:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` stack.pop()`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[j] = 0`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[i] -= 1`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` else`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:`:`})]}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` stack.pop()`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[j] = 0`})}),`\n`,_jsx(_components.span,{className:`line`,children:_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[i] = 0`})}),`\n`,_jsxs(_components.span,{className:`line`,children:[_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:` return`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` [remaining[i] `}),_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`for`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` i `}),_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`in`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` range(len(positions)) `}),_jsx(_components.span,{style:{color:`#D73A49`,\"--shiki-dark\":`#F97583`},children:`if`}),_jsx(_components.span,{style:{color:`#24292E`,\"--shiki-dark\":`#E1E4E8`},children:` remaining[i] > 0]`})]}),`\n`]})})}),`\n`,_jsx(Heading,{level:`2`,id:`complexity`,children:`Complexity`}),`\n`,_jsxs(Table,{children:[_jsx(_components.thead,{children:_jsxs(_components.tr,{children:[_jsx(_components.th,{children:`Time`}),_jsx(_components.th,{children:`Space`})]})}),_jsx(_components.tbody,{children:_jsxs(_components.tr,{children:[_jsx(_components.td,{children:`O(n log n)`}),_jsx(_components.td,{children:`O(n)`})]})})]}),`\n`,_jsx(Heading,{level:`2`,id:`tags`,children:`Tags`}),`\n`,_jsxs(_components.p,{children:[_jsx(_components.a,{href:`/catalog/neetcode`,children:`NeetCode All`}),`.`]})]})}function MDXContent(props={}){const{wrapper:MDXLayout}={..._provideComponents(),...props.components};return MDXLayout?_jsx(MDXLayout,{...props,children:_jsx(_createMdxContent,{...props})}):_createMdxContent(props)}return{default:MDXContent};function _missingMdxReference(id,component){throw new Error(`Expected `+(component?`component`:`object`)+\" `\"+id+\"` to be defined: you likely forgot to import, pass, or provide it.\")}","frontmatter":{},"scope":{"codeStyling":{"theme":{"light":"github-light","dark":"github-dark"}},"config":{},"pageMetadata":{"title":"Robot Collisions Python Solution with Tests","description":"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.","href":"/problems/robot-collisions"}}},"mdxSourceWithNoJs":null},"mdxExtracts":{"tableOfContents":[{"title":"Problem","slug":"problem","depth":2,"children":[{"title":"Examples","slug":"examples","depth":3,"children":[]},{"title":"Constraints","slug":"constraints","depth":3,"children":[]}]},{"title":"Solution","slug":"solution","depth":2,"children":[]},{"title":"Complexity","slug":"complexity","depth":2,"children":[]},{"title":"Tags","slug":"tags","depth":2,"children":[]}],"codeExamples":{}},"jsLinks":[],"subdomain":"leetcode-py","siteName":"leetcode-py","title":"Robot Collisions Python Solution with Tests - leetcode-py","navMaps":{"firstHrefInVersion":{},"firstHrefInLanguage":{}},"lastModified":"2026-09-07T03:04:53.871Z","gitLastModified":"2026-09-07T03:04:07.000Z","originalFileLocation":"problems/robot-collisions.mdx"},"headHtml":"\u003cscript data-mint-head>(function(){var d=document.documentElement,p=null;if(!p){try{p=localStorage.getItem(\"isDarkMode\")}catch(e){}if(p==='true')p='dark';else if(p==='false')p='light';if(p!=='light'\u0026\u0026p!=='dark'\u0026\u0026p!=='system')p=\"system\"}var r=p==='system'?(matchMedia(\"(prefers-color-scheme: dark)\").matches?'dark':'light'):p;d.classList.remove(r==='dark'?'light':'dark');d.classList.add(r);d.setAttribute(\"data-theme-preference\",p)})();\u003c/script>\u003cmeta data-mint-head name=\"description\" content=\"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\">\u003cmeta data-mint-head name=\"application-name\" content=\"leetcode-py\">\u003cmeta data-mint-head name=\"generator\" content=\"Mintlify\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"192x192\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/android-chrome-192x192.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"apple-touch-icon\" type=\"image/png\" sizes=\"180x180\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/apple-touch-icon.png\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"16x16\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/favicon-16x16.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"32x32\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/favicon-32x32.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"shortcut icon\" type=\"image/x-icon\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/favicon.ico\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"192x192\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon-dark/android-chrome-192x192.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"16x16\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon-dark/favicon-16x16.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"32x32\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon-dark/favicon-32x32.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"shortcut icon\" type=\"image/x-icon\" href=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon-dark/favicon.ico\" media=\"(prefers-color-scheme: dark)\">\u003cmeta data-mint-head property=\"og:title\" content=\"Robot Collisions Python Solution with Tests - leetcode-py\">\u003cmeta data-mint-head property=\"og:description\" content=\"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\">\u003cmeta data-mint-head property=\"og:site_name\" content=\"leetcode-py\">\u003cmeta data-mint-head property=\"og:url\" content=\"https://leetcode-py.wisl.dev/problems/robot-collisions\">\u003cmeta data-mint-head property=\"og:type\" content=\"website\">\u003cmeta data-mint-head property=\"og:image\" content=\"https://leetcode-py.wisl.dev/img/brand/og-card-light.png\">\u003cmeta data-mint-head property=\"og:image:width\" content=\"1200\">\u003cmeta data-mint-head property=\"og:image:height\" content=\"630\">\u003cmeta data-mint-head name=\"twitter:card\" content=\"summary_large_image\">\u003cmeta data-mint-head name=\"twitter:title\" content=\"Robot Collisions Python Solution with Tests - leetcode-py\">\u003cmeta data-mint-head name=\"twitter:description\" content=\"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\">\u003cmeta data-mint-head name=\"twitter:image\" content=\"https://leetcode-py.wisl.dev/img/brand/og-card-light.png\">\u003cmeta data-mint-head name=\"twitter:image:width\" content=\"1200\">\u003cmeta data-mint-head name=\"twitter:image:height\" content=\"630\">\u003cmeta data-mint-head name=\"msapplication-config\" content=\"/mintlify-assets/_mintlify/favicons/leetcode-py/MPF4VdYq1xxotsp3/_generated/favicon/browserconfig.xml\">\u003cmeta data-mint-head name=\"apple-mobile-web-app-title\" content=\"leetcode-py\">\u003cmeta data-mint-head name=\"msapplication-TileColor\" content=\"#3776AB\">\u003clink data-mint-head rel=\"canonical\" href=\"https://leetcode-py.wisl.dev/problems/robot-collisions\">\u003clink data-mint-head rel=\"alternate\" type=\"application/xml\" href=\"/sitemap.xml\">\u003clink data-mint-head rel=\"alternate\" type=\"text/markdown\" href=\"/problems/robot-collisions.md\">\u003cscript data-mint-head type=\"application/ld+json\">{\"@context\":\"https://schema.org\",\"@graph\":[{\"@type\":\"Organization\",\"@id\":\"https://leetcode-py.wisl.dev/#organization\",\"name\":\"leetcode-py\",\"url\":\"https://leetcode-py.wisl.dev\",\"logo\":{\"@type\":\"ImageObject\",\"url\":\"https://mintcdn.com/leetcode-py/aJKJ4BOUnXP-zM3G/img/brand/leetcode-py-lockup.svg?fit=max\u0026auto=format\u0026n=aJKJ4BOUnXP-zM3G\u0026q=85\u0026s=34c74a404ed256642a54345a92489c97\"},\"sameAs\":[\"https://github.com/wislertt/leetcode-py\",\"https://pypi.org/project/leetcode-py-sdk/\",\"https://wisl.dev\"]},{\"@type\":\"WebSite\",\"@id\":\"https://leetcode-py.wisl.dev#website\",\"name\":\"leetcode-py\",\"url\":\"https://leetcode-py.wisl.dev\",\"publisher\":{\"@id\":\"https://leetcode-py.wisl.dev/#organization\"}},{\"@type\":\"WebPage\",\"@id\":\"https://leetcode-py.wisl.dev/problems/robot-collisions#webpage\",\"url\":\"https://leetcode-py.wisl.dev/problems/robot-collisions\",\"name\":\"Robot Collisions Python Solution with Tests\",\"description\":\"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\",\"dateModified\":\"2026-09-07T03:04:07.000Z\",\"isPartOf\":{\"@id\":\"https://leetcode-py.wisl.dev#website\"}},{\"@type\":[\"Article\",\"TechArticle\"],\"@id\":\"https://leetcode-py.wisl.dev/problems/robot-collisions#article\",\"headline\":\"Robot Collisions Python Solution with Tests\",\"name\":\"Robot Collisions Python Solution with Tests\",\"description\":\"Tested Python solution for LeetCode 2751 with 30 pytest cases. Generate a practice environment with lcpy.\",\"url\":\"https://leetcode-py.wisl.dev/problems/robot-collisions\",\"mainEntityOfPage\":{\"@id\":\"https://leetcode-py.wisl.dev/problems/robot-collisions#webpage\"},\"image\":\"https://leetcode-py.wisl.dev/img/brand/og-card-light.png\",\"dateModified\":\"2026-09-07T03:04:07.000Z\",\"publisher\":{\"@id\":\"https://leetcode-py.wisl.dev/#organization\"},\"isPartOf\":{\"@id\":\"https://leetcode-py.wisl.dev#website\"}}]}\u003c/script>\u003cscript data-mint-head type=\"application/ld+json\">{\"@context\":\"https://schema.org\",\"@type\":\"WebSite\",\"name\":\"leetcode-py\",\"creator\":{\"@type\":\"Organization\",\"name\":\"Mintlify\",\"url\":\"https://mintlify.com\"}}\u003c/script>","siteName":"leetcode-py","nav":{"global":null,"groups":[{"group":"Welcome","pages":[{"title":"LeetCode Practice Environments in Python","sidebarTitle":"leetcode-py","href":"/index"}]},{"group":"Getting Started","pages":[{"title":"Install the lcpy CLI via pip or uv","sidebarTitle":"Installation","href":"/getting-started/installation"},{"title":"lcpy Quickstart: First Problem in 5 Commands","sidebarTitle":"Quickstart","href":"/getting-started/quickstart"},{"title":"LeetCode Practice Environment vs a Bare Editor","sidebarTitle":"Why leetcode-py","href":"/getting-started/why-leetcode-py"}]},{"group":"Practice","pages":[{"title":"Anatomy of a problem","href":"/practice/problem-anatomy"},{"title":"Test LeetCode Solutions Locally with pytest","sidebarTitle":"Test locally","href":"/practice/test-locally"},{"title":"LeetCode Python Test Cases with pytest","sidebarTitle":"Testing","href":"/practice/testing"},{"title":"Visualizations","href":"/practice/visualizations"},{"title":"Notebooks","href":"/practice/notebooks"}]},{"group":"CLI","pages":[{"title":"lcpy CLI: Generate and List Problems","sidebarTitle":"lcpy","href":"/cli/lcpy"},{"title":"Blind 75, Grind 75, NeetCode and Others","sidebarTitle":"Collections","href":"/cli/collections"}]},{"group":"Catalog","pages":[{"title":"LeetCode Problem Catalog: All Collections","sidebarTitle":"Catalog","href":"/catalog/index"},{"title":"All LeetCode Problems in Python with Tests","sidebarTitle":"All Problems","href":"/catalog/all"},{"title":"Easy LeetCode Problems in Python with Tests","sidebarTitle":"Easy","href":"/catalog/easy"},{"title":"Medium LeetCode Problems in Python with Tests","sidebarTitle":"Medium","href":"/catalog/medium"},{"title":"Hard LeetCode Problems in Python with Tests","sidebarTitle":"Hard","href":"/catalog/hard"},{"title":"Topics","href":"/catalog/topics"},{"title":"Grind 75 in Python with Tested Solutions","sidebarTitle":"Grind 75","href":"/catalog/grind-75"},{"title":"Grind Collection in Python: Tested Solutions","sidebarTitle":"Grind","href":"/catalog/grind"},{"title":"Blind 75 in Python with Tested Solutions","sidebarTitle":"Blind 75","href":"/catalog/blind-75"},{"title":"NeetCode 150 in Python with Tested Solutions","sidebarTitle":"NeetCode 150","href":"/catalog/neetcode-150"},{"title":"NeetCode 250 in Python with Tested Solutions","sidebarTitle":"NeetCode 250","href":"/catalog/neetcode-250"},{"title":"NeetCode All in Python with Tested Solutions","sidebarTitle":"NeetCode All","href":"/catalog/neetcode"},{"title":"AlgoMaster 75 in Python with Tested Solutions","sidebarTitle":"AlgoMaster 75","href":"/catalog/algo-master-75"}]},{"group":"Contributing","pages":[{"title":"Add a New LeetCode Problem End to End","sidebarTitle":"Problem creation","href":"/contributing/problem-creation"},{"title":"Contributor Reference: bakefile Tasks","sidebarTitle":"bakefile","href":"/contributing/bakefile"}]},{"group":"Troubleshooting","pages":[{"title":"lcpy Errors and Troubleshooting","sidebarTitle":"Troubleshooting","href":"/troubleshooting/index"},{"title":"lcpy gen Error: Problem Not Found","sidebarTitle":"Problem not found","href":"/troubleshooting/unknown-problem"},{"title":"lcpy gen Error: Problem Already Exists","sidebarTitle":"Already exists","href":"/troubleshooting/files-already-exist"},{"title":"Visualizations Show ASCII Instead of Diagrams","sidebarTitle":"ASCII diagrams","href":"/troubleshooting/graphviz-missing"},{"title":"Playground Notebook Cells Do Not Render","sidebarTitle":"Notebook cells","href":"/troubleshooting/notebook-cells"}]}]},"basePath":"","title":"Robot Collisions Python Solution with Tests - leetcode-py","buildId":"dpl_42LwxxU1kGN114H4XzwGYXa9ZDah","deploymentId":"dpl_42LwxxU1kGN114H4XzwGYXa9ZDah","dynamics":["a74be98ba7"],"chunks":["zoom-image-lightbox-DkE6VzSN.js","lightbox-handle-r17bVUz3.js"]}